jetson posture system
camera bring-up, sensors, and pose inference on Jetson Orin Nano.
what i built
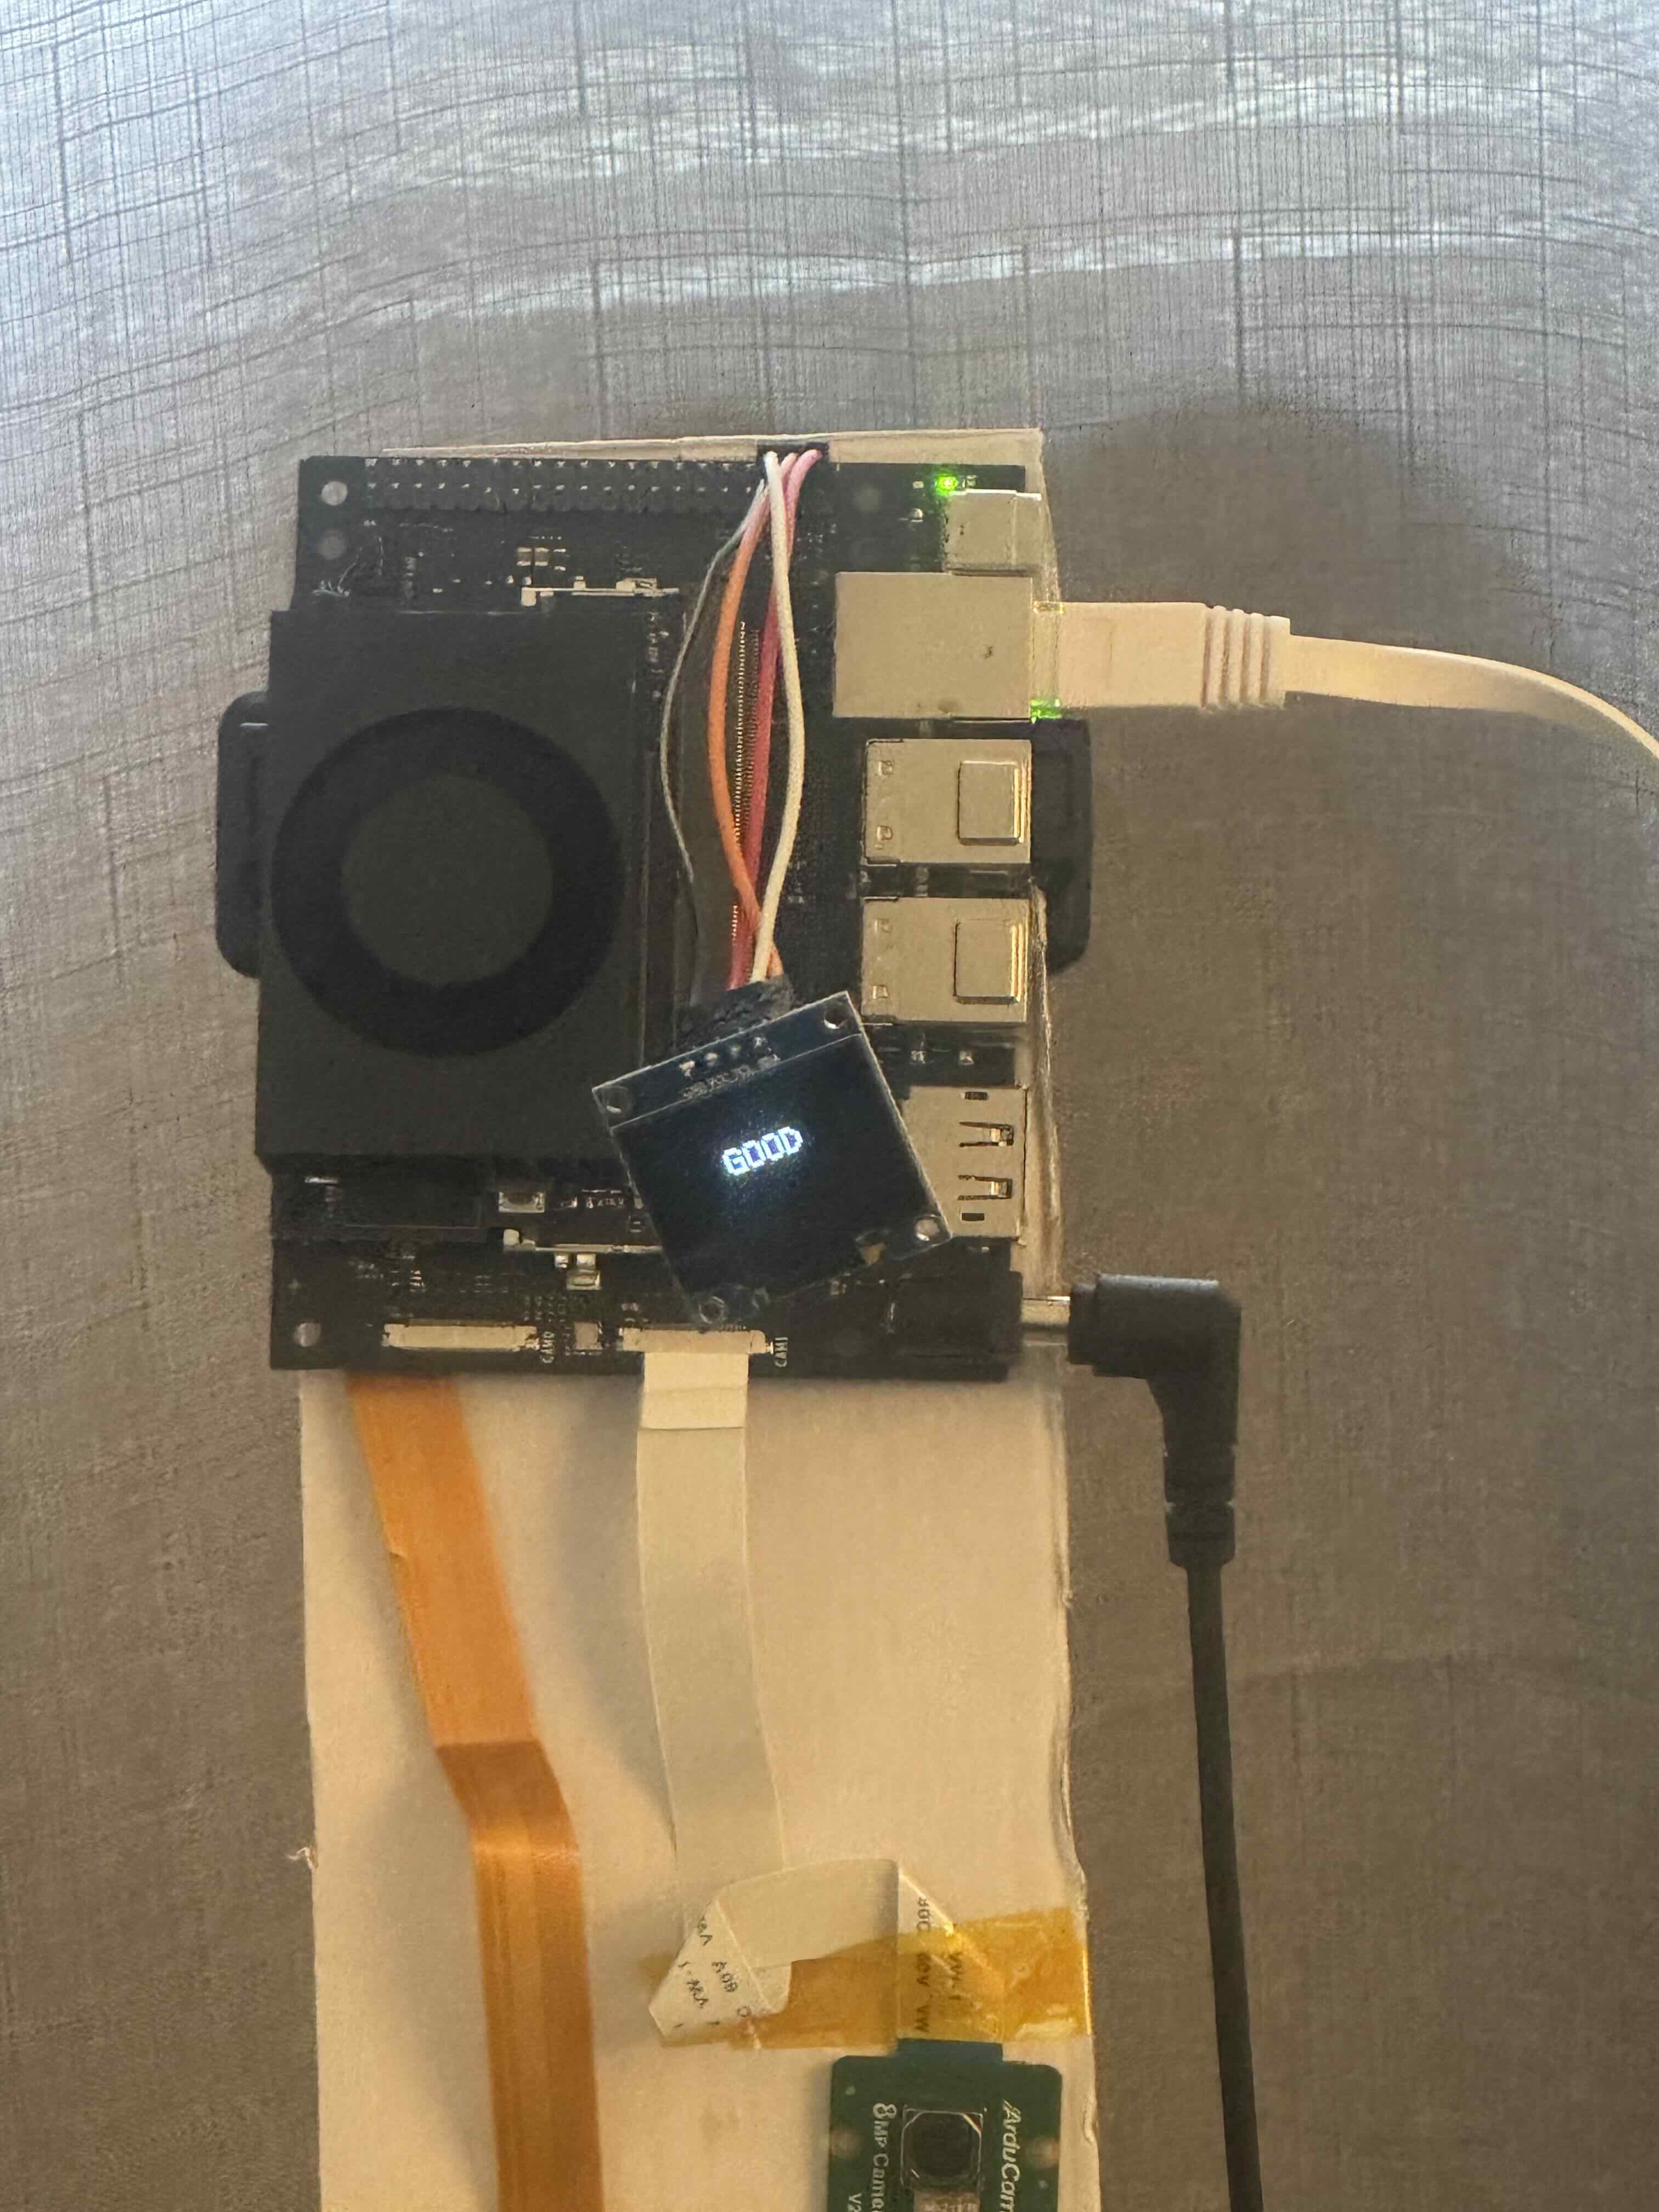
- CSI camera integration through Argus and GStreamer; I²C IMU, OLED, and GPIO feedback.
- C++20 sensor runtime with bounded queues and dropped-sample tracking.
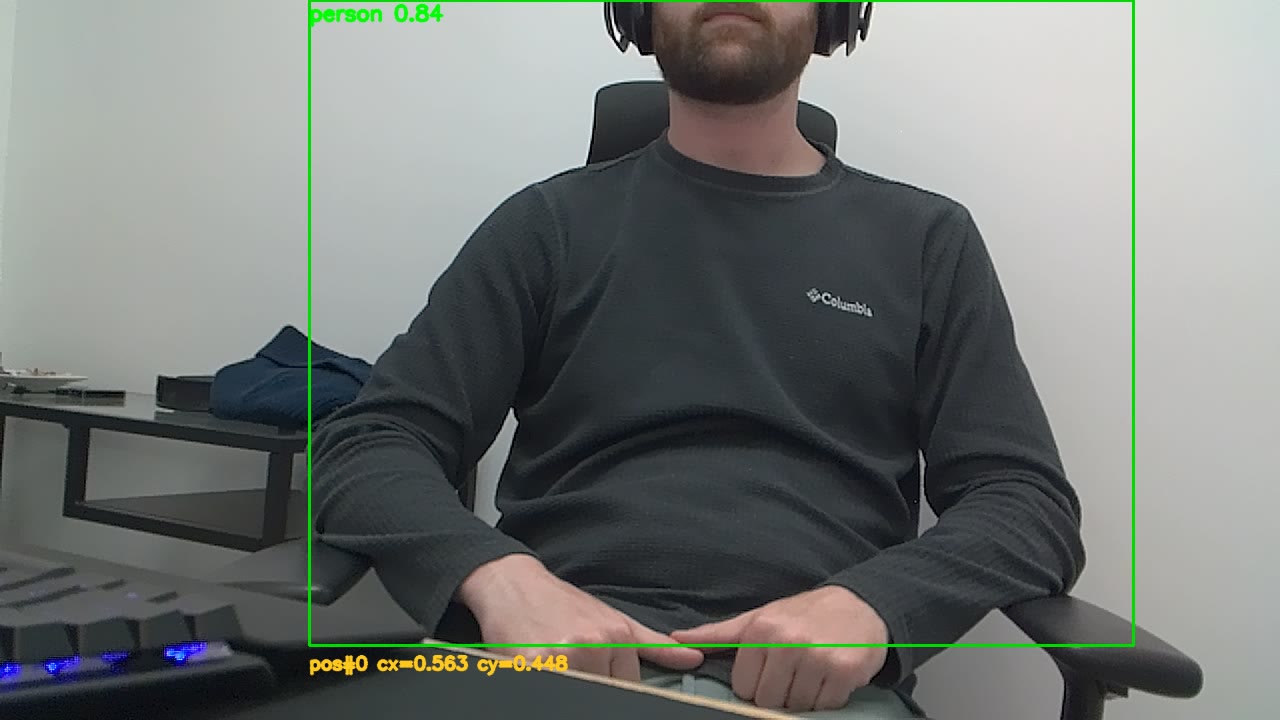
- Python pose classification, SQLite history, and systemd services.
what i learned
bus numbering, device-tree overlays, and pinmux state mattered as much as inference. setup notes capture those hardware fixes.
paused personal prototype. the C++ camera producer is simulated; the real camera pipeline runs in Python.